dennler [at] mit [dot] edu
[Twitter] | [Scholar] | [GitHub]
I am Nathan Dennler, a full-stack roboticist. I am a postdoctoral researcher at the Massachusetts Institute of Technology advised by Andreea Bobu. I am Nathan Dennler, a full-stack roboticist and postdoctoral researcher at the Massachusetts Institute of Technology advised by Andreea Bobu. My research develops algorithms that enable robots to adapt to individual users at deployment time. A robot’s broadly learned capabilities may not capture a particular person’s preferences, physical abilities, or household requirements, so I study how robots can learn these differences with little effort from the user. I ground my work in manipulation, rehabilitation, and socially assistive applications where physical robots interact with real users.
I approach personalization as an optimization problem whose specification is learned through interaction. My research addresses three questions: What features of robot behavior matter to a user? Which behaviors are acceptable for that person? How can a robot improve from the feedback they can provide? I develop methods for learning human-aligned representations, identifying personalized constraints, and efficiently optimizing robot behavior from noisy and incomplete feedback.
I also enjoy building open-source tools (e.g., PyLips and The MUFaSAA Dataset) to support robotics researchers and hobbyists. For a complete listing of my work, head over to my Research page.
I am on the 2027 faculty job market!
Previously, I developed AI systems at Uber that predicted user behaviors to optimize marketplace welfare across the globe. I received my PhD from the University of Southern California, where I was co-advised by Stefanos Nikolaidis and Maja Matarić. I also received a B.S. in Computer Science and a B.Eng. in Robotics Engineering from Worcester Polytechnic Institute. In my spare time, you can find me find me figure skating at Johnson Athletic Center, designing and sewing garments in my living room, running along the Charles, or whacking/waacking/punking in any of the aforementioned spaces. If you want to see me do any of these things (and more!), check out my Miscellany page.
News:
- Oct 2026: I was selected as a NERC Rising Star.
- Jul 2026: Organized the RSS Pioneers Workshop with Lukas Schmid at RSS!
- Jun 2026: Organized Community Building Day with Andrea Sipos at ICRA!
- Mar 2026: I gave a talk on Robot Faces at the Vizij Workshop at HRI 2026!
- Mar 2026: I gave a talk at the Cornell Robotics Seminar!
- Sept 2025: I attended the UC Berkeley NextProf Nexus program.
- May 2025: I was awarded the Order of the Laurel and the Palm at USC for leadership and service that shaped the campus and the world at large.
Selected Publications
Journal Papers
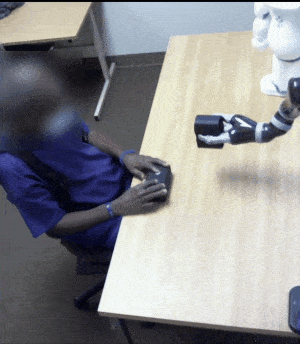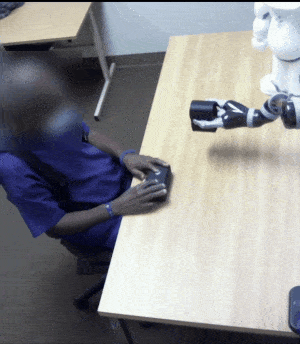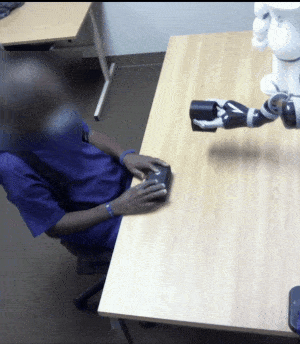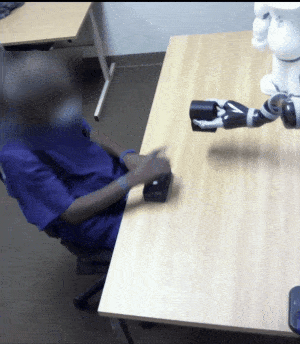
A metric for characterizing the arm nonuse workspace in poststroke individuals using a robot arm
Nathaniel Dennler, Amelia Cain, Erica De Guzman, Claudia Chiu, Carolee Winstein, Stefanos Nikolaidis, and Maja Matarić.
Science Robotics 8, eadf7723(2023). DOI:10.1126/scirobotics.adf7723.
[free access]
Conference Papers